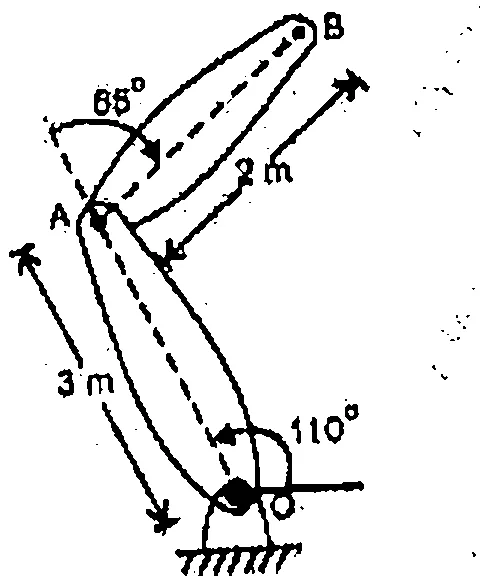
Q.6 (B) A simple 2 DOF planar robot is shown. Prepare a D H parameter table and perform forward kinematics to find the location and orientation of end effector B.
Every question from past university papers on Introduction to Robot Kinematics, newest paper first. Open any question for its full worked answer.
Q.6 (B) A simple 2 DOF planar robot is shown. Prepare a D H parameter table and perform forward kinematics to find the location and orientation of end effector B.
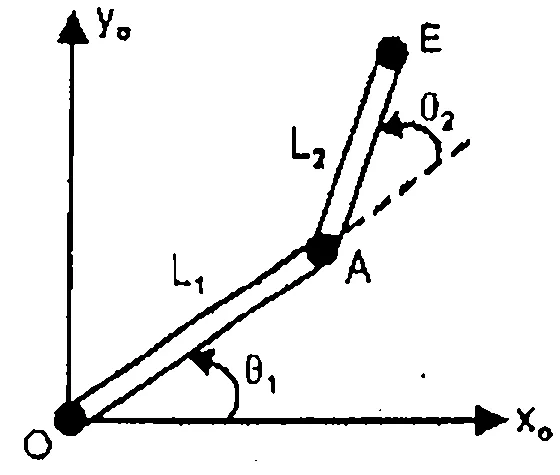
Q.6 (A) A planar elbow manipulator is shown. Write the D H parameters and hence locate the position and orientation of the end E of the manipulator. Given \(L_1 = L_2 = 250\) mm and \(\theta_1 = \theta_2 = 30^\circ\).